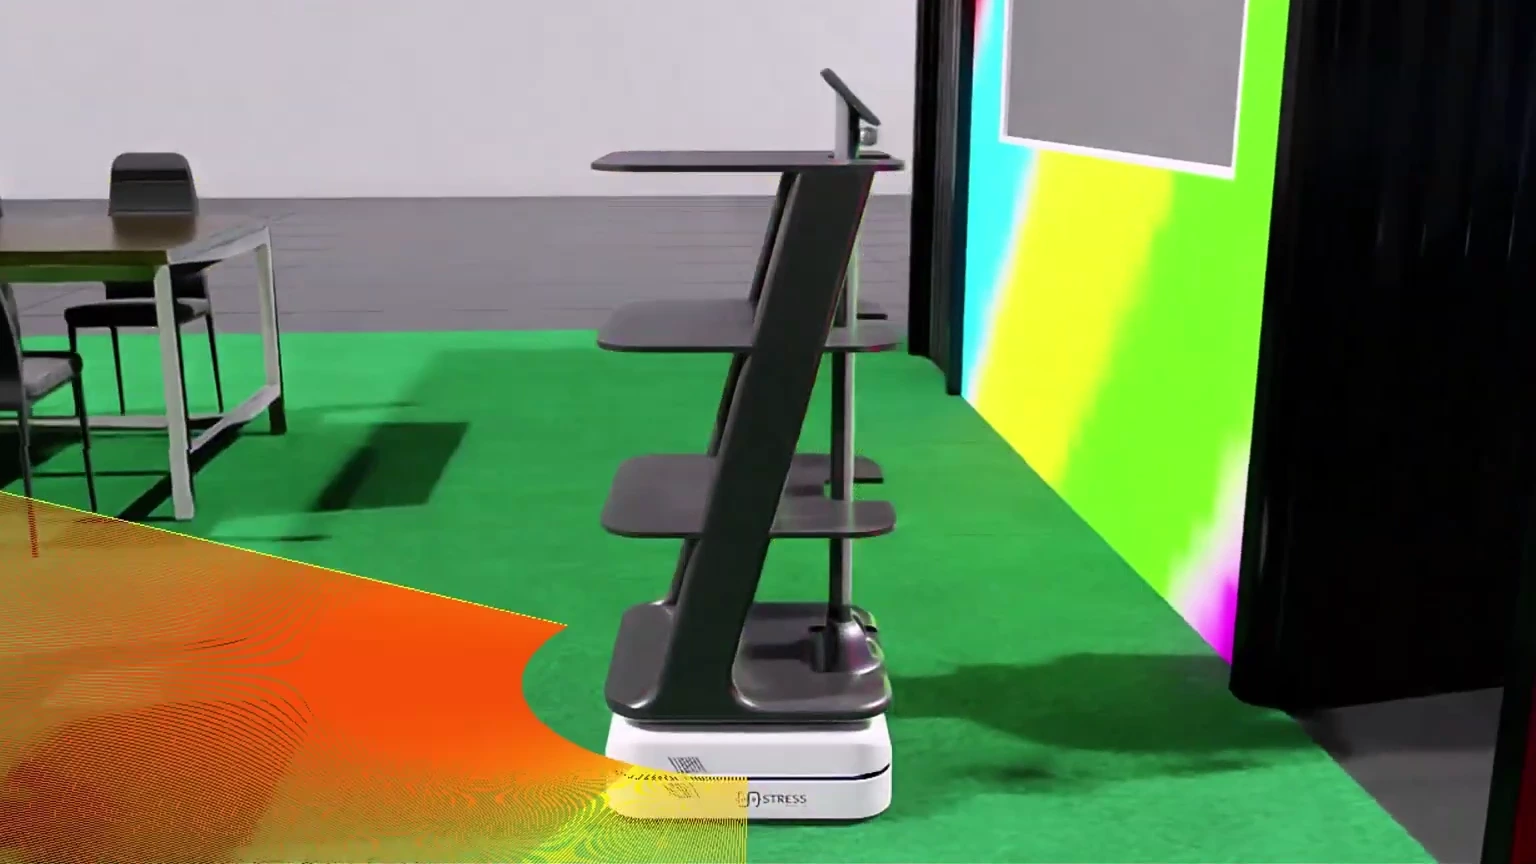
Zero service robot & digital twin
A service-robot model and a lab digital twin for exploring robot behaviour before fabrication.
Top 10 · NVIDIA / LycheeAI competition, 2025
01 / Portfolio
From first prototypes to virtual worlds. A selection of my own research and work developed with teams.
A service-robot model and a lab digital twin for exploring robot behaviour before fabrication.
Top 10 · NVIDIA / LycheeAI competition, 2025
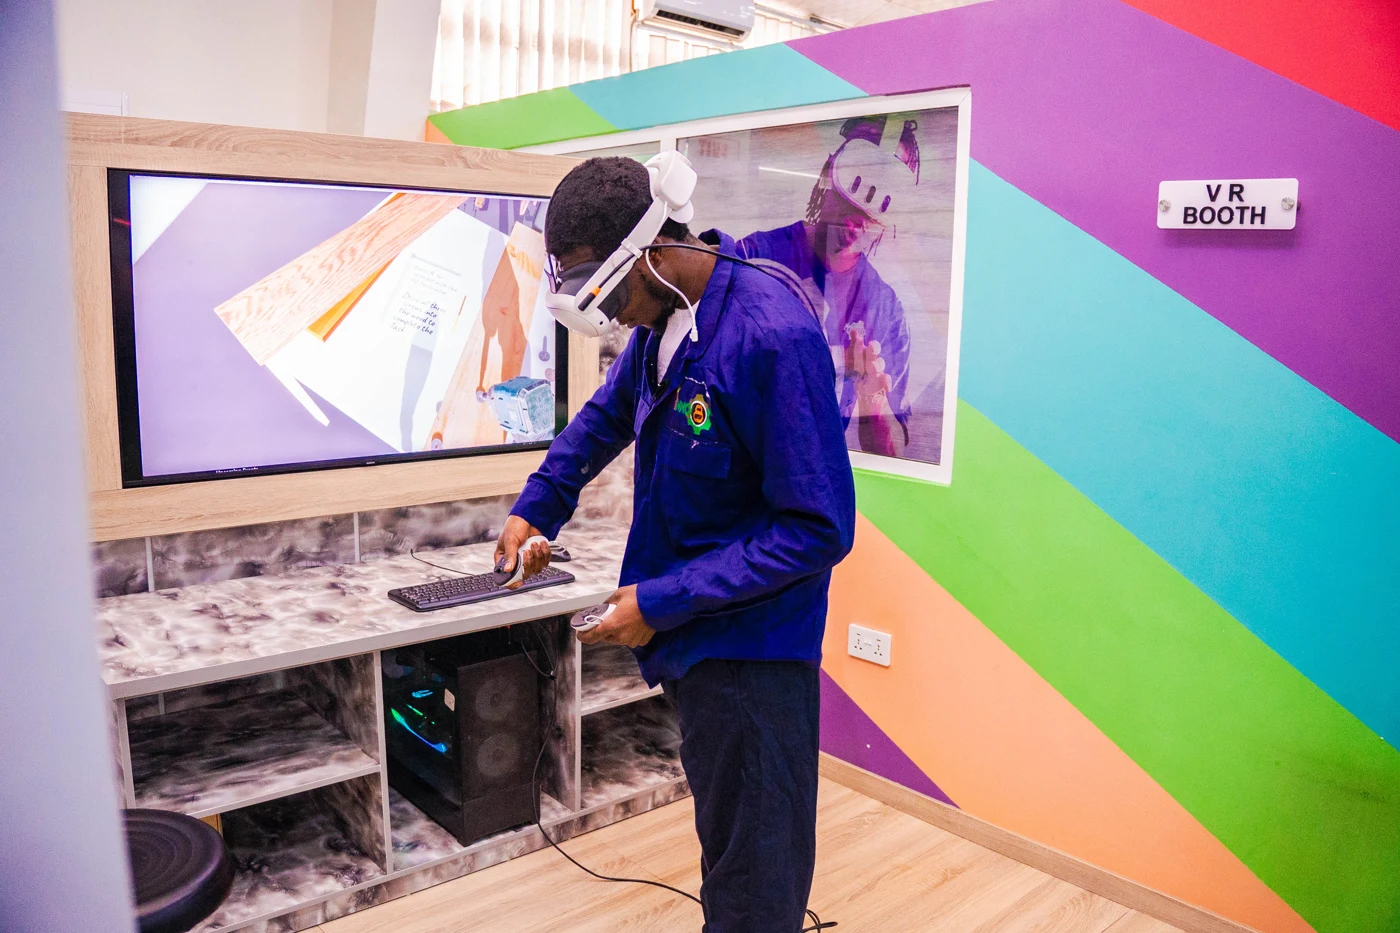
A voice-first vocational training prototype with workshop activities and a conversational AI tutor.
1st place · IEEE Metaverse Grand Challenge, 2025
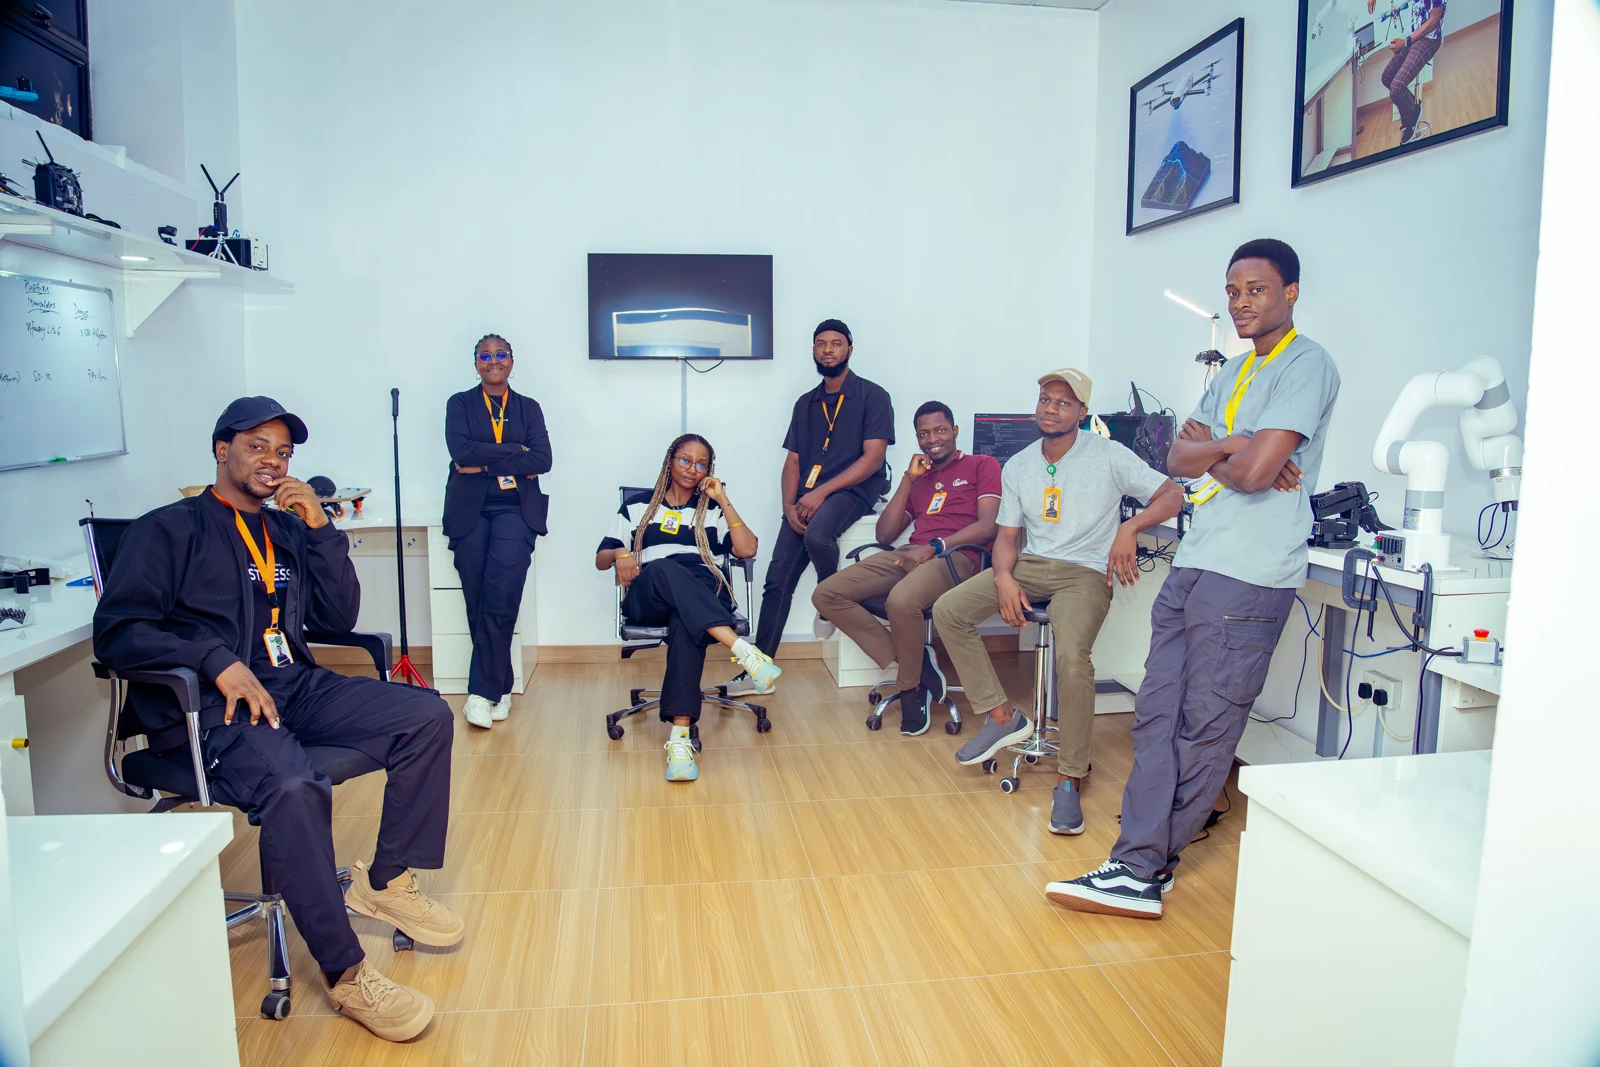
Designing and establishing the Product Design, Simulation and Robotics labs at Innov8 Hub.
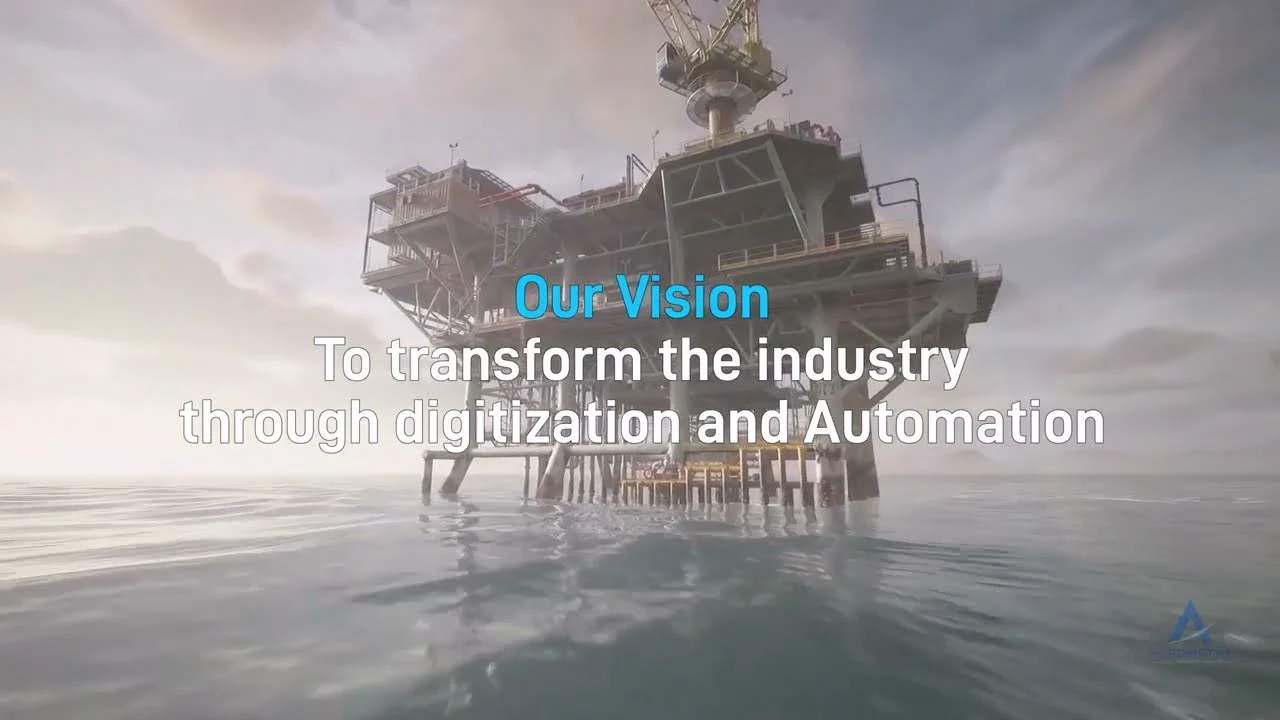
Industrial asset-intelligence demos connecting spatial records, inspection findings and engineering information.
02 / Capabilities
I work across hardware, software and spatial experiences—connecting the parts that make an idea work.
Robot design, embedded integration and prototyping. From mechanical assemblies and sensors to ROS 2 workflows, navigation and teleoperation.
See robotics projects ↗Virtual testbeds that make systems easier to understand and develop. Physics, sensors and robot control in Isaac Sim and Gazebo; reality-captured environments and asset-information demos.
Explore virtual testbeds ↗Interactive training prototypes, conversational VR and design-review experiences. Built with Unreal Engine, with practical activities and approachable interactions at the centre.
Step into the work ↗Product animations, 360 tours and 3D reconstruction. I also plan and establish labs around the workflows of the people who will use them.
View visualisation projects ↗04 / The person behind the work
Stress Robotics is how I share what I build, explore and learn. My work moves between robotics, simulation and spatial computing, with a focus on practical tools for learning and industry.
I’ve established and led product design, simulation and robotics labs, developed award-winning VR work, and built platforms for hands-on experimentation.
My background & CVs ↗